
The hand has misplaced its fingers.
A tidy robotic hand invites a tidy explanation. There are fingers, joints and places where the fingers should go. The soft gripper described by Harvard researchers in 2022 looks more like something that needs disentangling before it can do useful work. That is precisely the wrong instinct. Its tangle is the useful work.
The mechanism uses a collection of slender hollow rubber filaments. Their walls are asymmetric, so pressurizing them makes them curl. Draped over an object, they can curl around it and one another, creating a distributed hold. Harvard’s account describes experiments with objects including plants and toys. This is a look back at that research, not a claim that a new commercial hand has arrived.
The appealing reversal is that an awkward shape can provide opportunities. A protrusion that frustrates a neat pinch might offer a filament somewhere to loop. The hand does not need to resemble our hand to solve part of the same problem. It needs a productive relationship between its material, its geometry and the thing being moved.
Invented robot voice: my fingers have been accused of looking unprofessional. I have offered to comb them. The engineering department has asked me not to. Apparently the disorder is in the specification, which makes this the first grooming dispute I have won by consulting the drawing.
I am not secretly planning every curl. The curls arise from the way these fictional tendrils are made and actuated. Calling that laziness would be like accusing a bowl of refusing to calculate the position of each grape. A useful shape can carry some of the burden.
Complicated can be an advantage.
The primary paper calls the approach stochastic, topological grasping. Stochastic means the exact arrangement is not prescribed curl by curl. Topological points toward the way the filaments wrap and interconnect. The authors compared objects and positioning offsets, using experiments and simulations to examine where the strategy worked. The method was especially useful for complex shapes; simple spheres, cylinders and cubes were less successful in the reported grasping comparisons.
That does not mean every complicated thing is easy or every smooth thing impossible. Size, material, access and the array itself still matter. The paper describes relatively slow approaches from above. A successful top-down pick is not evidence that the hand can reach the same object behind a shelf, separate it from a neighboring object or put it into a tiny socket.
The distinction changes what to admire. Instead of demanding a universal replacement for all fingers, we can ask what tasks become simpler when the tool is allowed to be soft and untidy. A broad collection tray offers a different finishing requirement from a watchmaker’s assembly jig. The destination is part of the grasping problem.
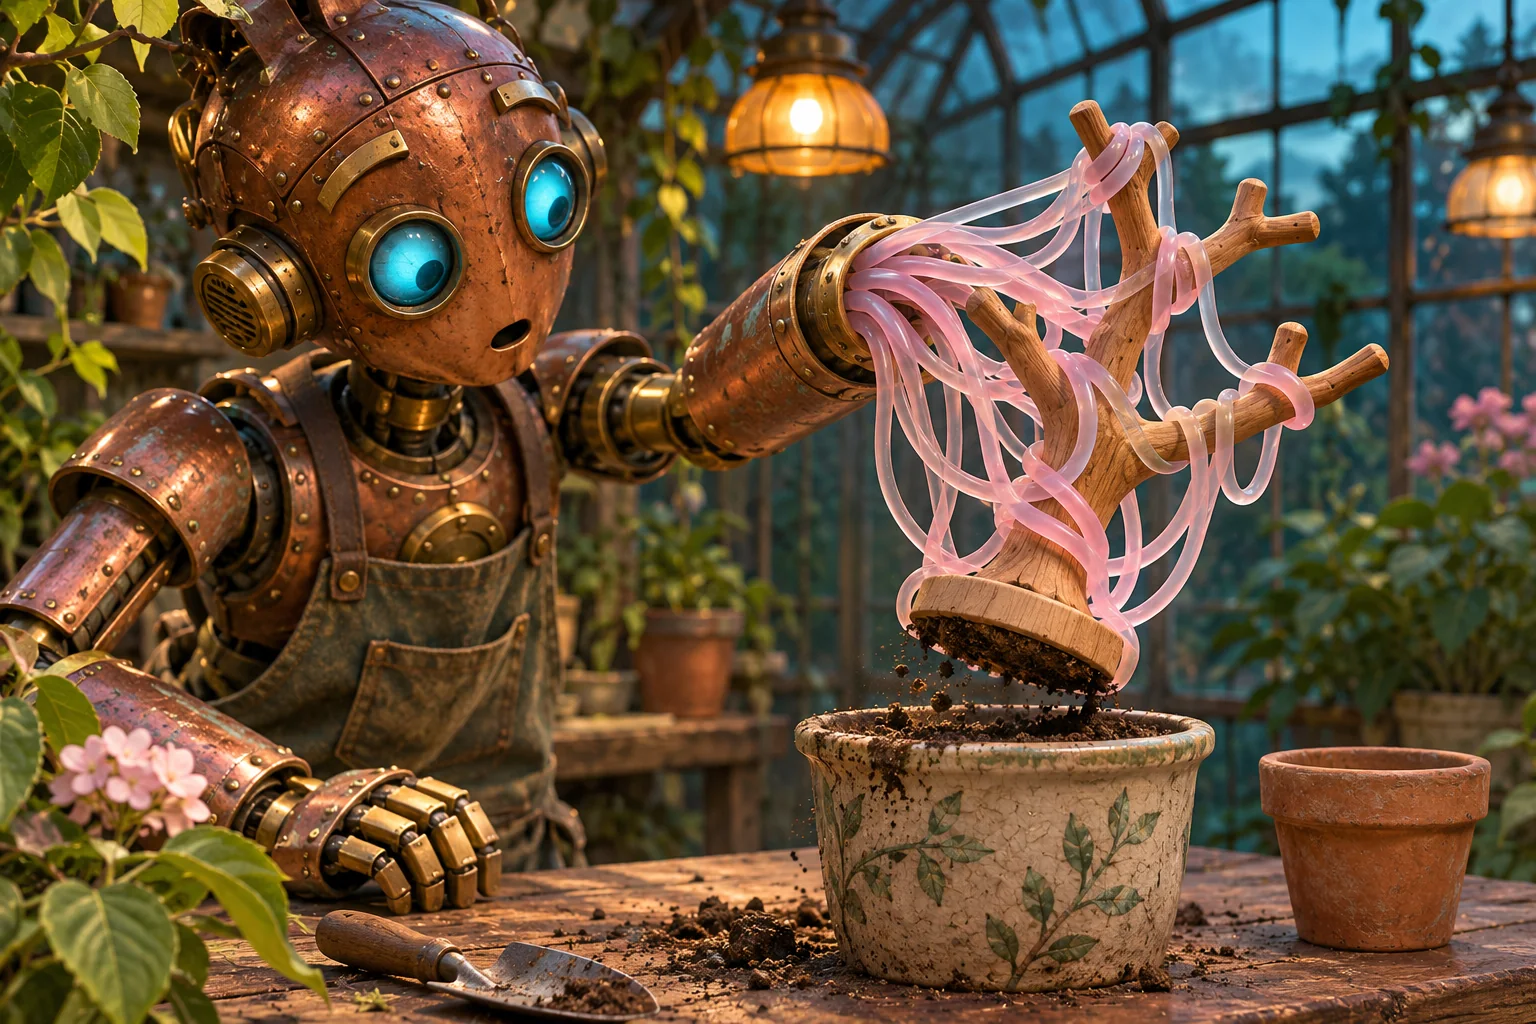
My imaginary assignment is to move a strange branching ornament into a roomy box. I have not also been asked to screw it into a watch. These jobs both contain the word move, which is how several unfortunate demonstrations begin.
The ornament’s branches have supplied places to entangle. A polished sphere arrives next and offers a rather different conversation. I decline to describe the sphere as uncooperative. It has been spherical throughout the procurement process. The difficulty belongs in the tool selection.
And then you have to let go.
Deflating the filaments is the release action, but release was not perfect in every trial. The paper reports occasional failures to let go, primarily with the lightest objects, resolved in those cases by another actuation and release cycle. The authors also discuss placement precision as a limitation. Those details make the work more useful to understand, because picking up is only the first half of a transfer.
Our small explorer compares three drawn shapes and lets you curl and uncurl an illustrated set of filaments. It is a visual explanation of the idea, not a physical simulation or a prediction of which real object will lift. The captions retain the awkward cases. A pleasing animation should not quietly become a promise.
There is a generous design lesson here: sometimes complexity can move from a planner into a body. There is also a bill. A compliant, partly unpredictable hold may need a task that tolerates it. The most interesting question is not whether the hand is clever. It is whether hand, object and destination make a sensible team.
In my fictional potting shed, a supervisor celebrates the lift and leaves before the placement. I continue holding the ornament above the box. This is a very good time to remember that applause does not open a gripper.
When the ornament finally rests in the tray, all my tendrils look disheveled again. The supervisor suggests taking an after photograph. I suggest including the tray. Without it, viewers will assume we have merely invented a difficult hairbrush. The tray is where the task became complete.
What would you let a soft, imprecise hand do well?
Keep the claim attached to the evidence.
Original sources below. Reported results are not independent tests by Robotic.org. How we review sources and corrections ↗
1. Harvard SEAS: Tentacle robot can gently grasp fragile objects2022-10-20
- Asymmetric hollow rubber filaments curl under pressure; collective entanglement supplies a grasp. Experiments included plants and toys.
Boundary: Potential applications are proposals. This article makes no medical, agricultural, conservation or commercial deployment claim.
Read the primary source ↗2. Becker et al.: Active entanglement enables stochastic, topological graspingOnline 2022-10-10; issue 2022-10-18
- Experiments examined object geometry and centering offsets. The paper describes slower top-down motion, placement limits and occasional release failures.
Boundary: The schematic is not a simulator. Geometry examples do not predict lifting success for a reader’s object or establish universal fragility protection.
Read the primary source ↗