
Listen before squeezing.
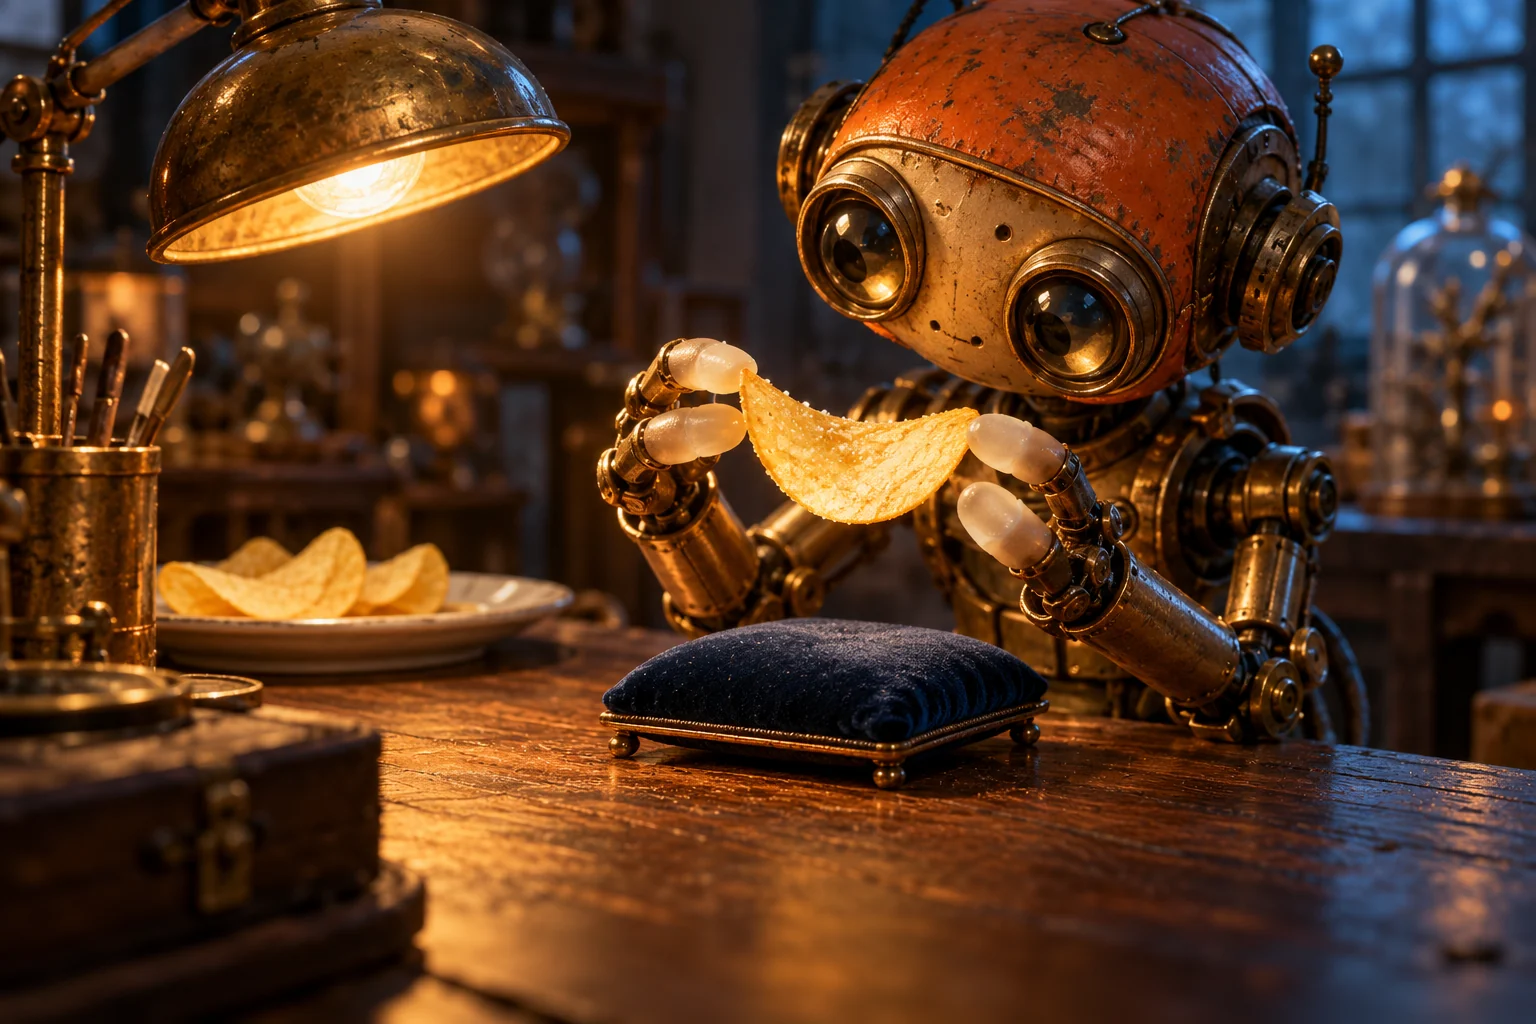
A potato chip is an excellent robotics examiner. It offers no partial credit for confidence.
Carnegie Mellon researchers built fingertips that sense squeezing force and contact vibrations. A strain gauge measures pressure; a microphone behind a plastic fingernail picks up the tiny vibrations produced by touching and sliding. Soft silicone provides grip.
The fingertip combines a strain gauge, a microphone behind a plastic fingernail and a soft silicone contact surface. Force and vibration provide different information about a grasp.
Keep the price attached to the part.
In reported tests, the fingertips helped manipulate fragile objects including chips and tofu, and count and separate stacked paper cups when vision was obstructed. Touch becomes a source of information, not merely the moment the camera's plan meets the table.
These are research components attached to a robotic hand, not a household helper you can order. The reported cost of under US$100 per fingertip describes the research build, not the retail price of a complete robot. The snack remains a demanding customer.
The reported demonstrations include fragile-object manipulation and stacked-cup handling. A reported build cost below US$100 per fingertip does not include an entire robotic hand or household system.
Invented robot voice: “Object secured. Object intact. Human requested a crisp result. Keeping that phrase out of the force controller.”
What everyday object would make the hardest gentle-grasp test?
Keep the claim attached to the evidence.
Original sources below. Reported results are not independent tests by Robotic.org. How we review sources and corrections ↗
1. CMU: Researchers give robots a delicate touch2026-10-05
- The fingertip combines a strain gauge, a microphone behind a plastic fingernail and a soft silicone contact surface. Force and vibration provide different information about a grasp.
- The researchers' project describes force and vibration sensing, closed-loop grasping, cup handling and hidden-material identification. Everyday general-purpose dexterity remains a research goal.
Boundary: Research prototype; no consumer price. Under US$100 per fingertip is a reported construction cost, not an offer.
Read the primary source ↗2. Research team: A Multi-modal Tactile Fingertip DesignAuthor project page; date not stated
- The fingertip combines a strain gauge, a microphone behind a plastic fingernail and a soft silicone contact surface. Force and vibration provide different information about a grasp.
- The researchers' project describes force and vibration sensing, closed-loop grasping, cup handling and hidden-material identification. Everyday general-purpose dexterity remains a research goal.
Boundary: Research prototype; no consumer price. Under US$100 per fingertip is a reported construction cost, not an offer.
Read the primary source ↗